Concept
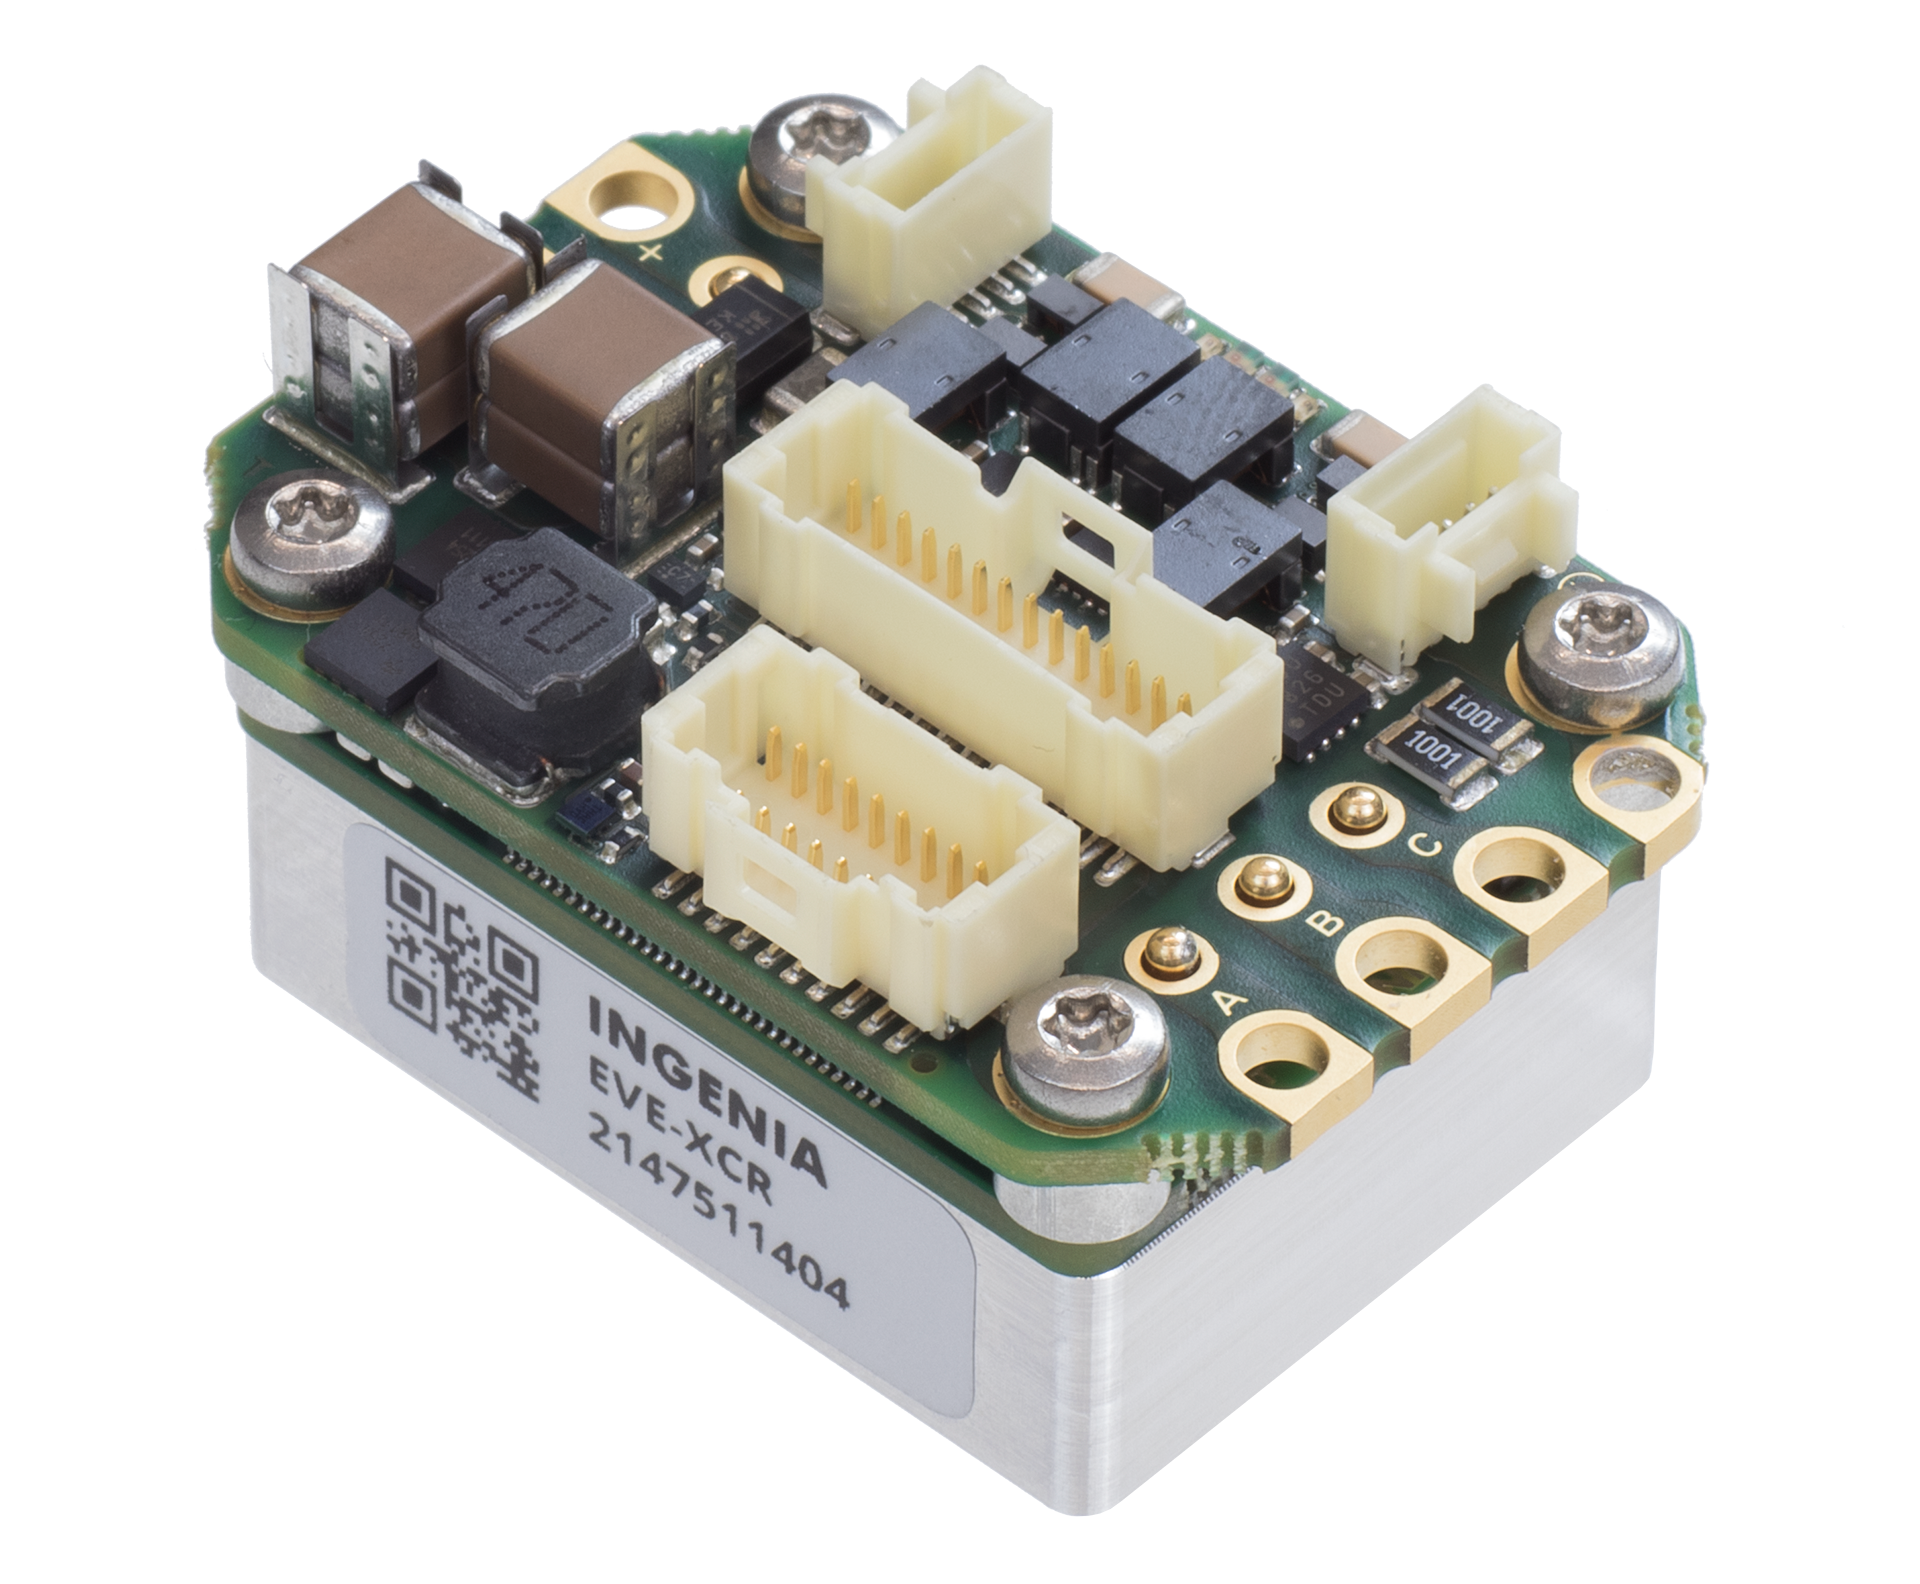
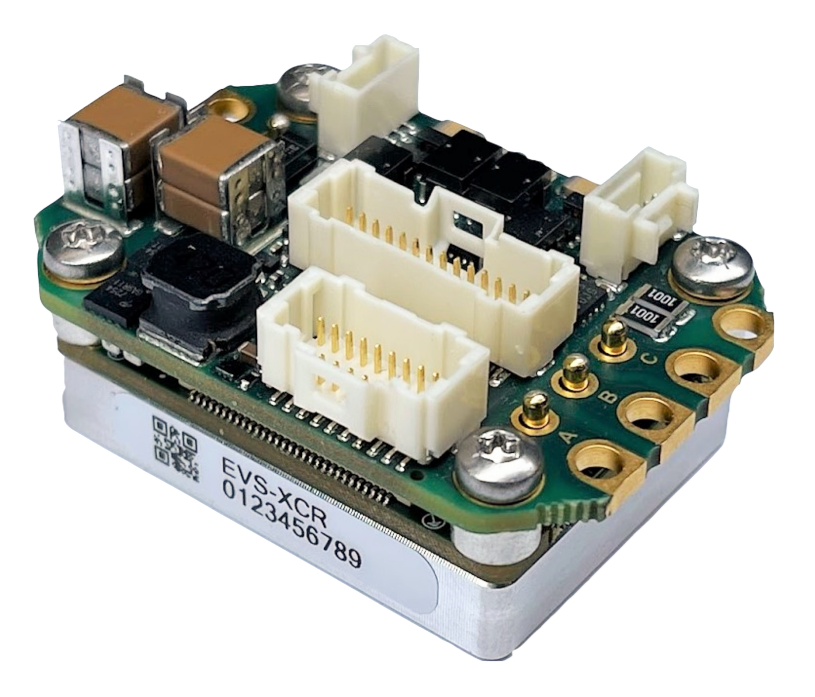
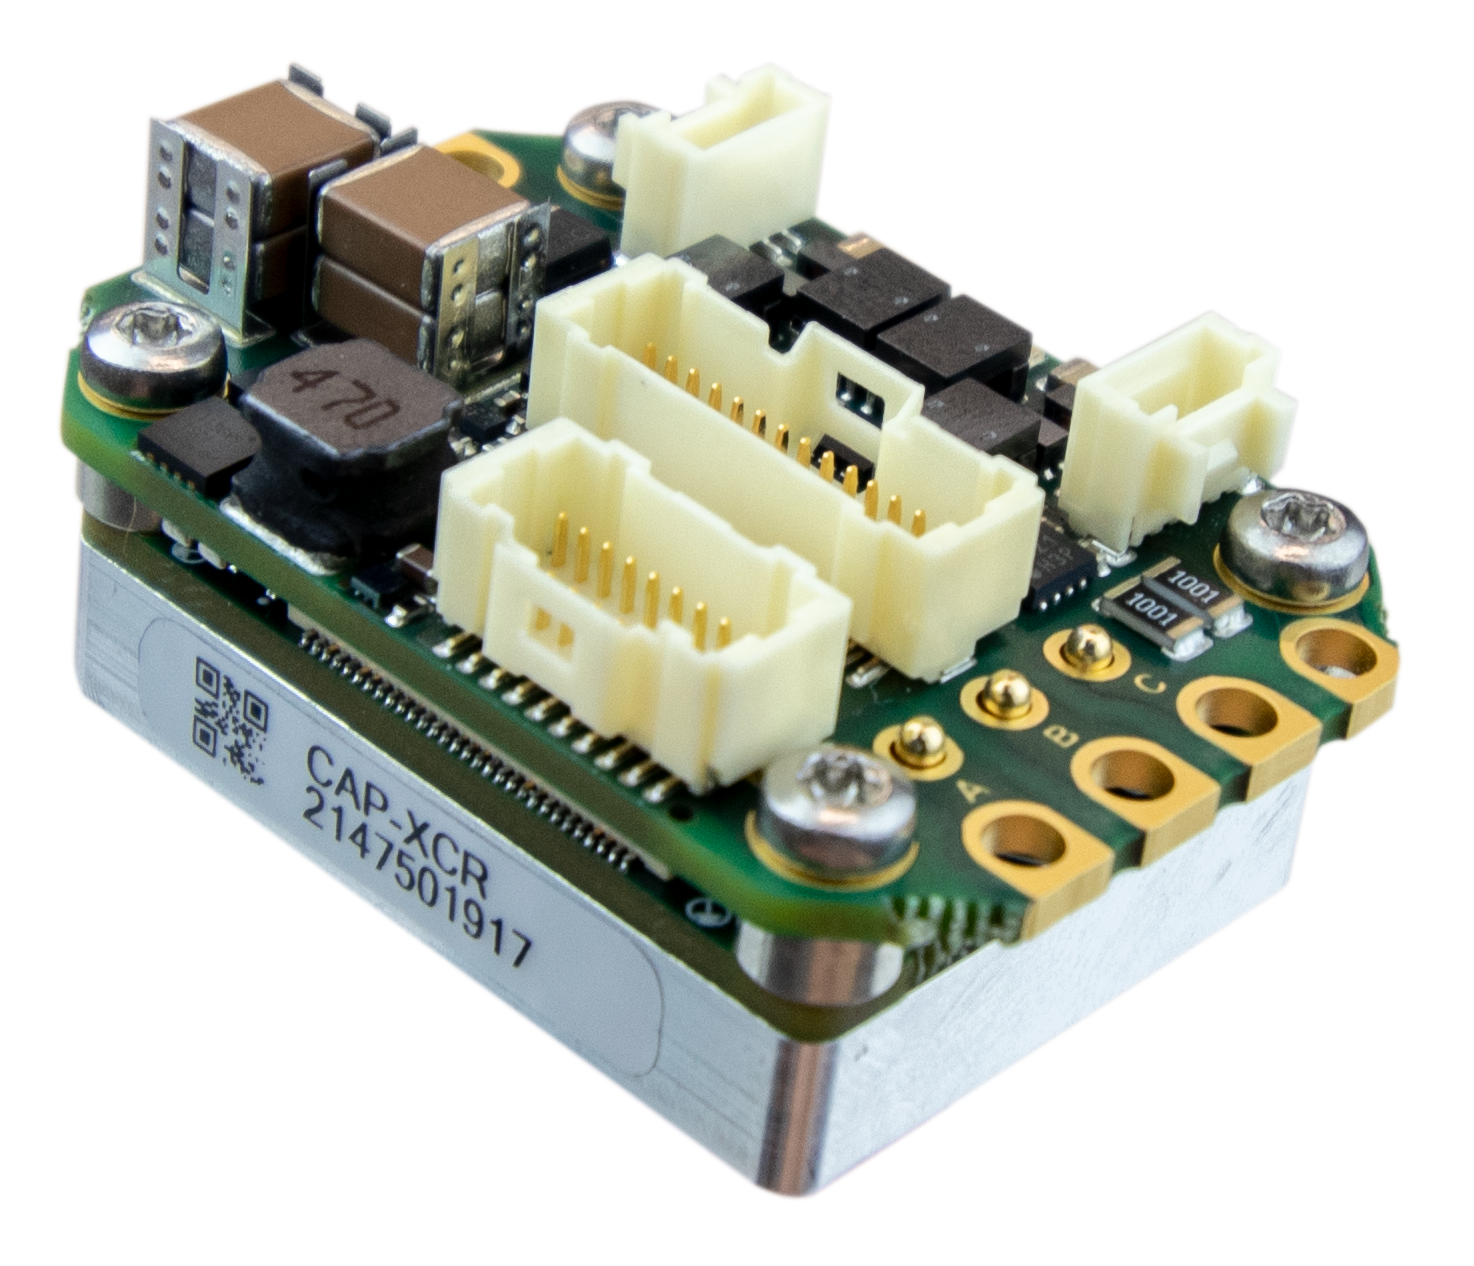
Among the Summit Collection of drives, each drive series includes an “XCR” version. The XCR is an auxiliary circuit board that provides all the connectors, transceivers, and adapter electronics necessary to interface with nearly all the functionality available within the “NET” drive. The NET module integrates the power stage, motion controller, and communication layer into a single unit. The present application example covers an interface board 100% compatible with Everest NET, Everest S NET, and Capitan NET miniature drives.
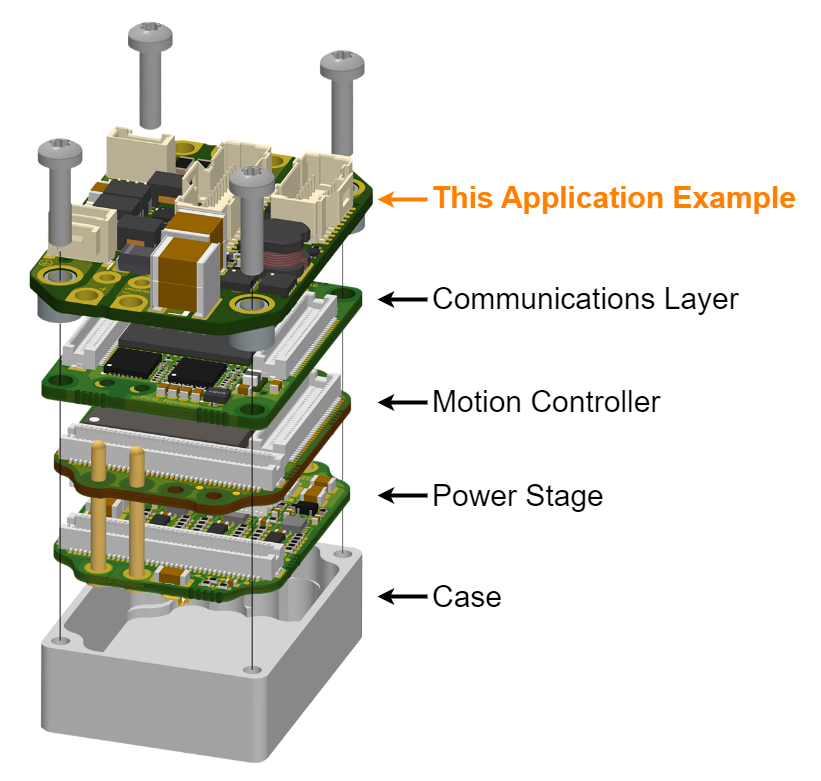
Although compact and confined, the proposed interface board is intended to grant access to a multi-purpose set of features; it does not address the needs of a specific application; rather, it provides a universal approach through which Summit drives can be adapted to a wide variety of application scenarios where vertical connectivity is required. Despite its small size, it can pipe the full current rating of Everest and Everest S NET, allows connectivity for both EtherCAT and CANopen product versions, contains the required DC/DCs for single or dual supply schemes, and includes all the necessary protections to make the drive rugged in front of a harsh electrical environment.
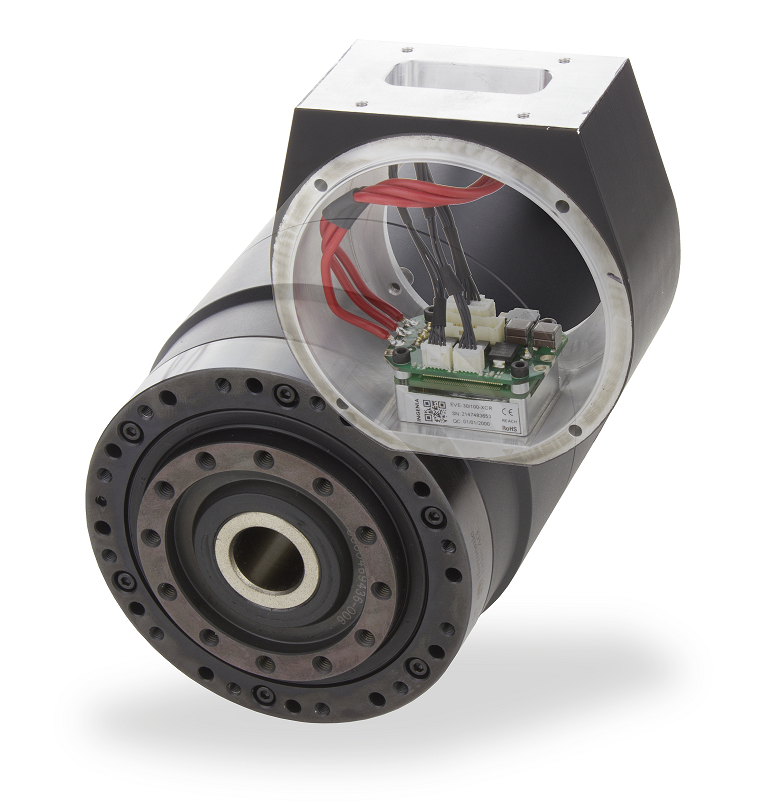
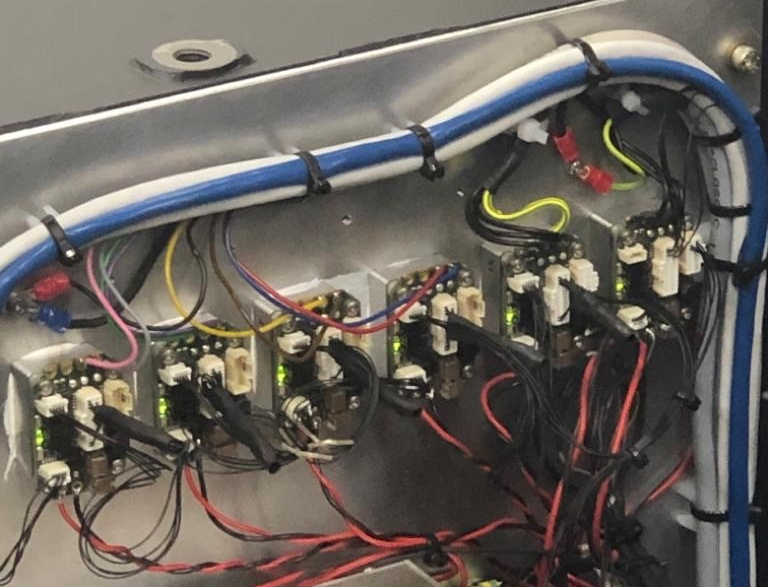
By means of the present guide, this versatile interface board is made freely available to anyone who wants to start straight using Summit drives. Usage details, design criteria, and general advice are given through the following pages.
Key features & advantages
-
Ultra-small footprint, yet easy connectivity
-
Multi-purpose universal set of features
-
Support for single or dual supply schemes
-
Up to 80 VDC, 45 A continuous
-
Supports digital halls, quadrature incremental encoder, SSI, and dual BiSS-C (up to 4 simultaneous)
-
CAN and Ethernet physical layers for CANopen and EtherCAT communications
-
4x digital inputs, 4x digital outputs, and 1x analog input
-
Dedicated motor temperature sensor input and electromechanical brake output
-
Dedicated redundant Safe Torque Off inputs (STO SIL3 PLe)
-
Full voltage, current, and temperature protections
Typical applications
-
Collaborative robot joints
-
Robot grippers & end effectors
-
Robotic exoskeletons & wearable robots
-
Cartesian robots & CNC machines
-
AGVs, AMRs & e-Mobility
-
UAVs
-
Highly integrated & smart servomotors
-
Heavy-duty gimbals or stabilizers
-
Low inductance motors
-
Lab equipment
Specifications
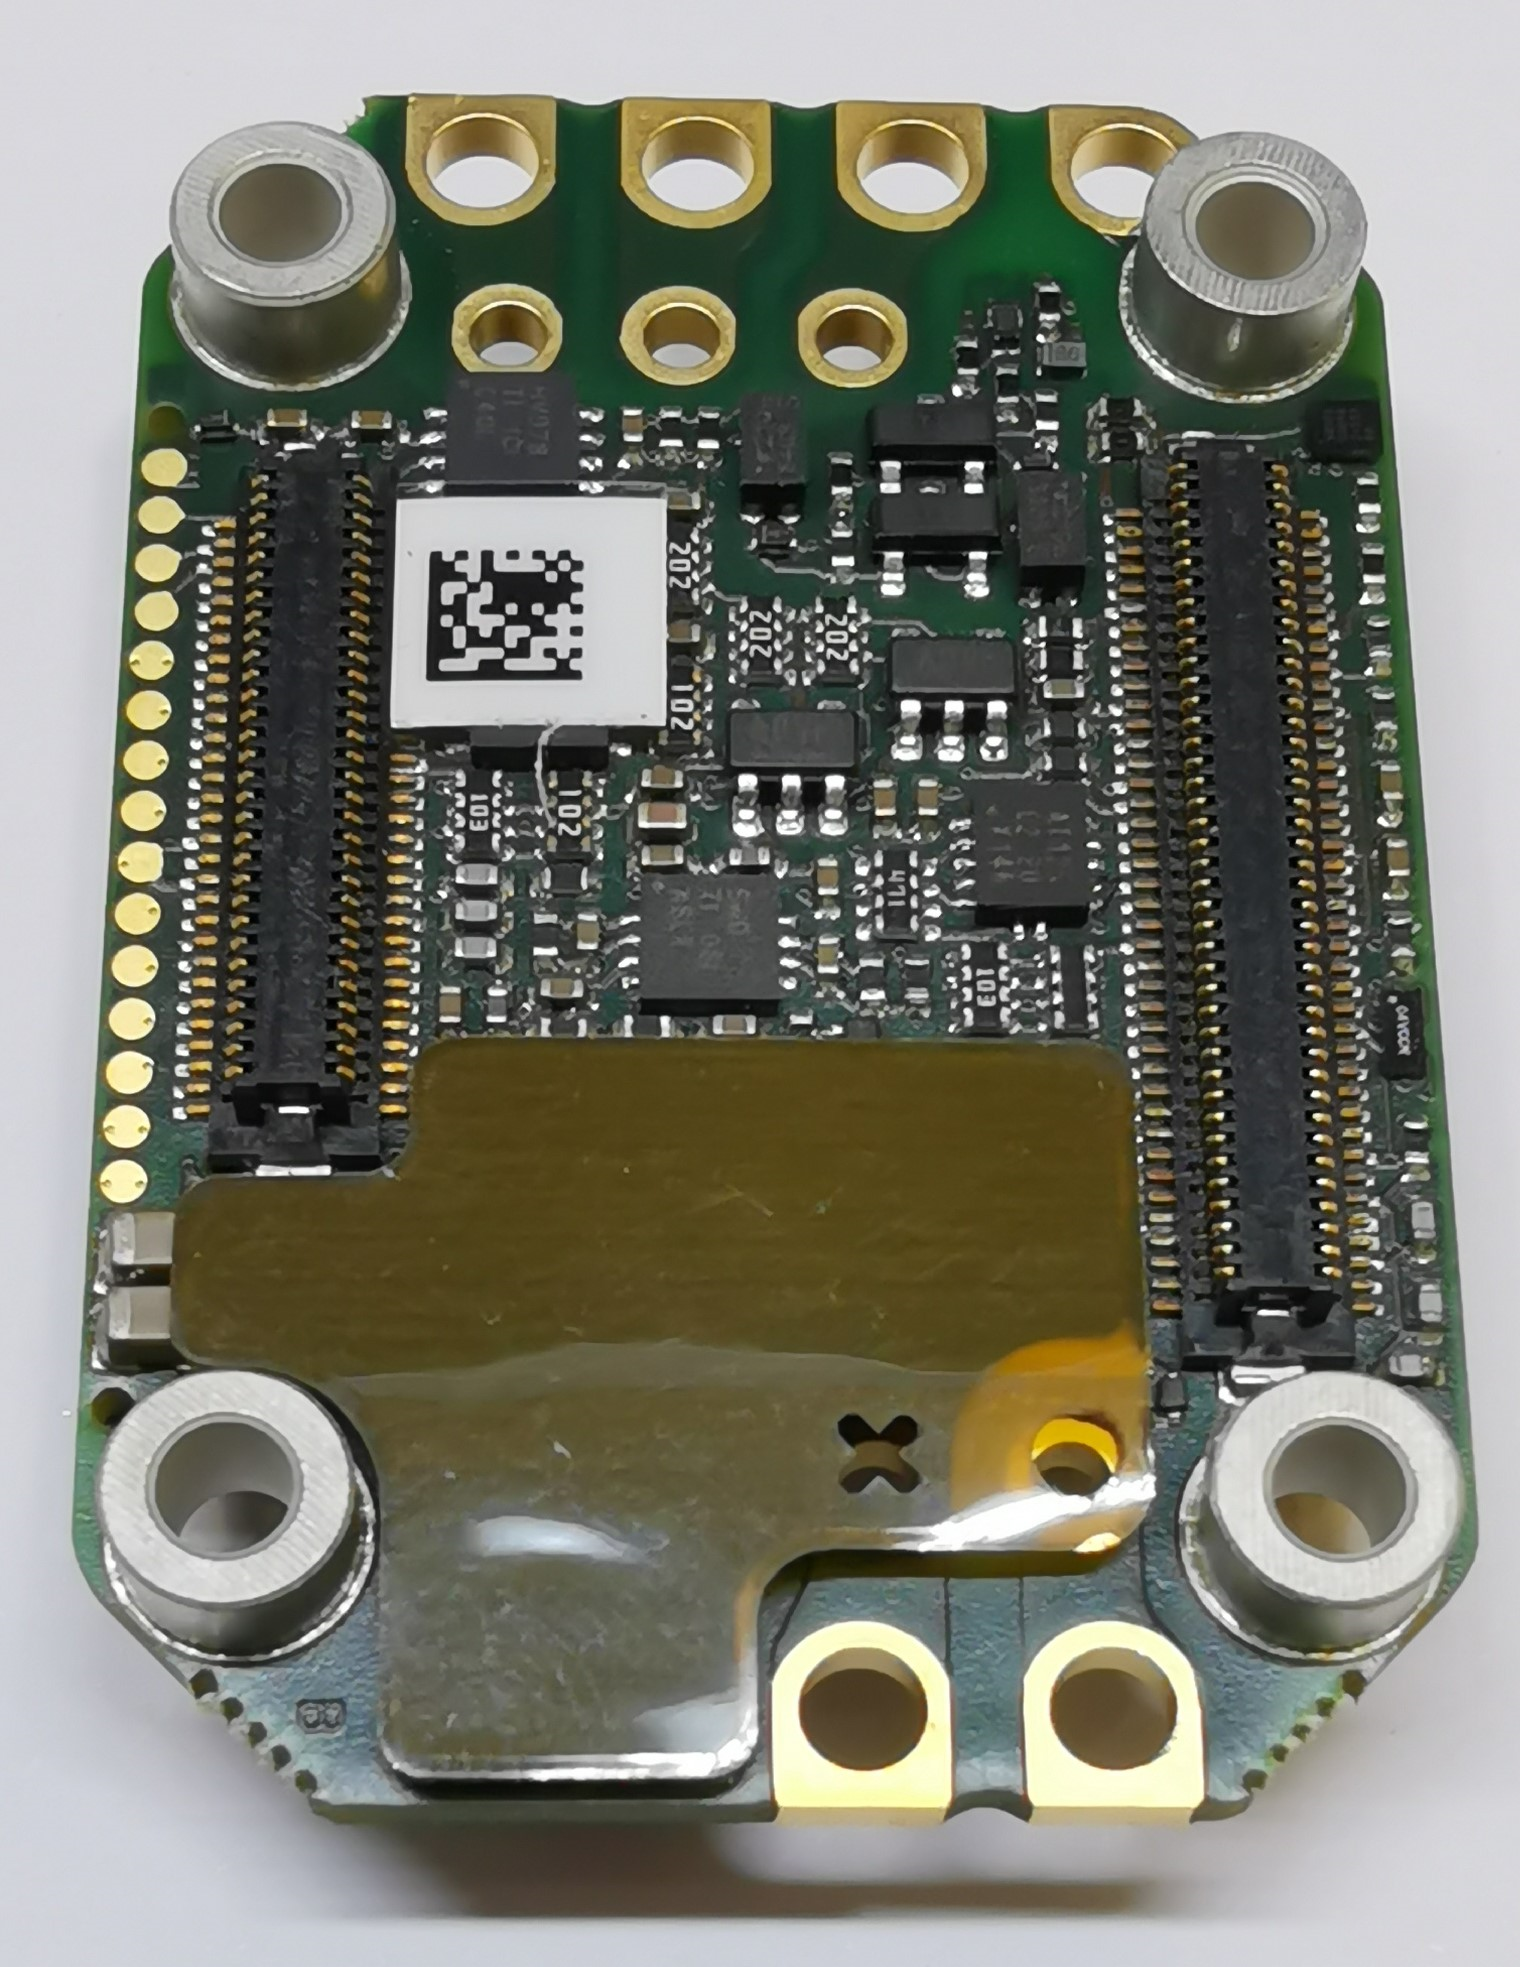
The Single Axis Interface Board of this application example consists of the “XCR” interface board and a flexible PCB acting as a shield to avoid coupling noise from the “XCR” to the communications board. The shield is mandatory for the correct operation of the system. The shield should be mounted as in the following picture:
See the Mechanical Specifications section of this guide for further details on the physical characteristics of the design.
Refer to the links below to get the full set of resulting features and specifications for the combination of this interface board with each of the compatible Summit drives.