Warning: This project, i058D-H1-2.3.0, includes a variant named SAFETY_COMPATIBLE, which enables compatibility with the DEN-S-NET drive. However, this variant does not fulfill the safety integration requirements and should only be considered as a starting point for development. For detailed information regarding the safety integration requirements, please refer to the Safety Integration chapter of the Application Guide.
This document is associated and shall be used together with the main Summit Designer Application Guide.
Its purpose is to serve as a complementary guide, where some of the circuits, recommendations, and resources from the main Application Guide are implemented into the resolution of a specific application; in this case, a single-axis interface board compatible with Denali NET. The Guide offers the set of resources required to obtain a manufacturable design of a practical PCB capable of interfacing most of the features and capabilities of the drive and ready to be embedded in a minimal space inside the robot.
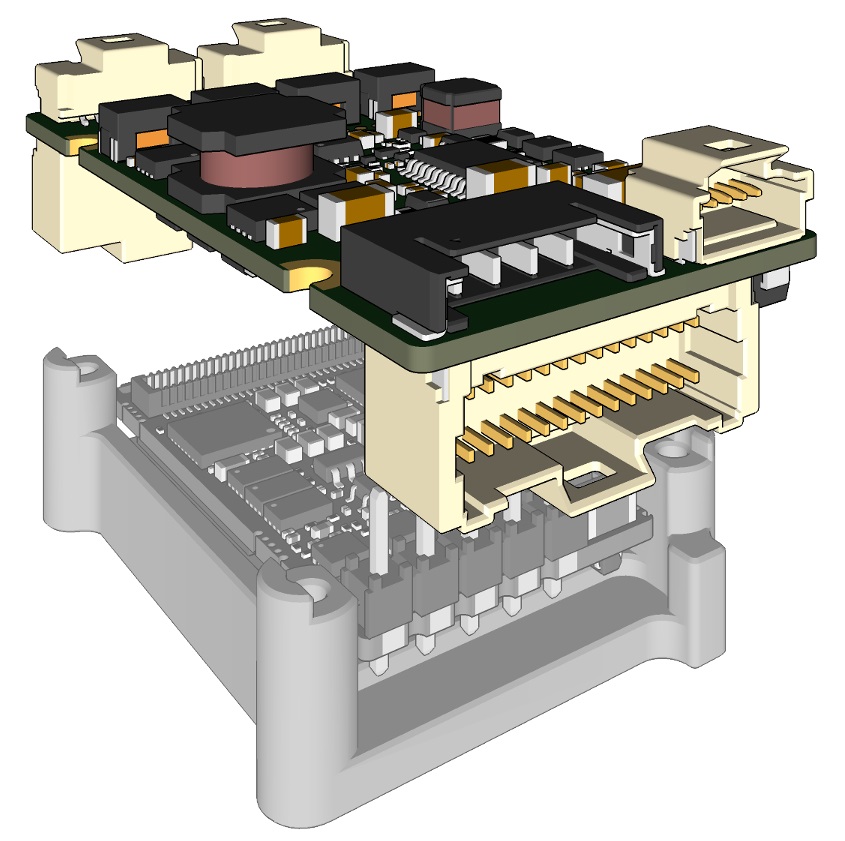
Not only context design notes and criteria are given, but the full project fonts including Schematic, PCB layout, Manufacturing outputs, and 3D Models are available to download. Hence, the user does not need to start from scratch, taking the risk of making errors in the process, but only modifying a finished and tested design with the minimum changes required to adapt it to a specific context.
Through the proposed carrier board, the advanced motion control capabilities and exceptional power density of the Denali NET platform can be readily leveraged. Combined with the inherent advantages of EtherCAT and CANopen communication networks, this solution provides an efficient and highly integrated approach for embedding a state-of-the-art smart servo drive within an extremely compact form factor.
To have the most up-to-date information, always use this Design Guide in combination with the Denali NET Product Manual.